
Why Bad Grounding Looks Like a Bad Encoder

When a servo system starts throwing encoder faults, the encoder usually takes the blame. It gets swapped out. The system runs clean for a day or two, and then the faults come back. So the drive goes out for repair. That comes back fine. Meanwhile, the problem has been sitting in the cable tray the whole time — a grounding or shielding issue that produces symptoms no one can distinguish from a failing encoder without knowing what to look for.
Why servo systems are so sensitive
Servo feedback signals (encoder pulses, resolver outputs, etc.) operate at low voltage and high frequency. The same pulse-width modulation (PWM) switching that gives a servo drive its precision also generates high-frequency common-mode noise that needs somewhere to go. A properly grounded system gives it a controlled path out.
When that path doesn’t exist or wasn’t installed correctly, the noise finds the feedback cables instead. That’s when the drive starts seeing what looks like corrupted encoder data.
What it looks like on the floor
Grounding problems produce a recognizable pattern once the maintenance team knows what to look for. If the fault pattern fits any of these, the encoder is probably not the problem:
- Intermittent encoder faults that clear on power cycle with no physical change to the encoder (A genuine encoder failure rarely self-resolves this cleanly.)
- Position or following errors that appear only under load or at speed, when drive switching current increases and noise generation goes with it
- Faults that correlate with other equipment running nearby, like a VFD starting across the room, a welding cell cycling, or a large motor coming online
- Systems that fault more frequently after a machine move, panel reconfiguration, or cable replacement, any of which can disturb a ground connection that was marginal to begin with
Where grounding goes wrong
Most grounding failures in servo systems come from a short list of installation mistakes that get repeated across the industry:
- Shield termination done with a pigtail wire instead of a 360-degree clamp defeats the shield at the frequencies that matter most. The pigtail introduces inductance that lets noise through.
- Feedback cable shields grounded at both ends without accounting for ground potential differences create a loop that actively conducts noise rather than blocking it.
- Signal cables routed in the same tray as motor power cables pick up radiated interference along their entire run, regardless of how well the shield is terminated at the ends.
- Ground connections made to painted or anodized panel surfaces, rather than bare metal, add resistance that makes the ground path unreliable under high-frequency conditions.
How to confirm before replacing anything
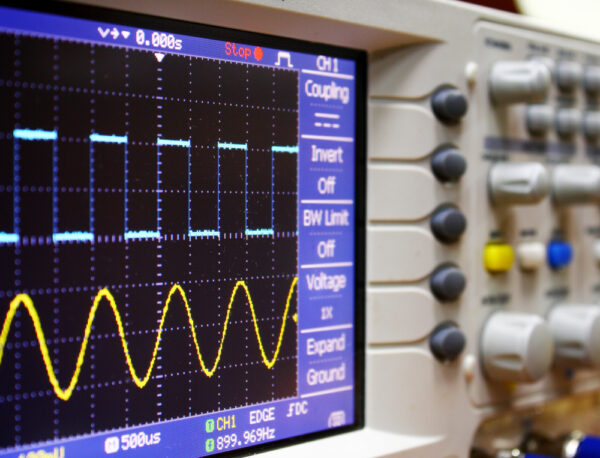
A multimeter and an oscilloscope answer the question fast. Measure ground potential difference between the drive chassis and the controller. Anything above roughly 1V suggests a ground loop worth investigating. Check shield continuity end-to-end with a low-ohm meter. Then put an oscilloscope on the encoder signal lines while the system runs. Noise riding the signal is visible immediately. If it cleans up when the shield is properly clamped at a test point, the diagnosis is done.
Remember, the drive’s fault code reflects what it experienced, not what caused it. Grounding problems earn that encoder fault code over and over, and no replacement encoder changes the underlying math.
